
Humpback Orca
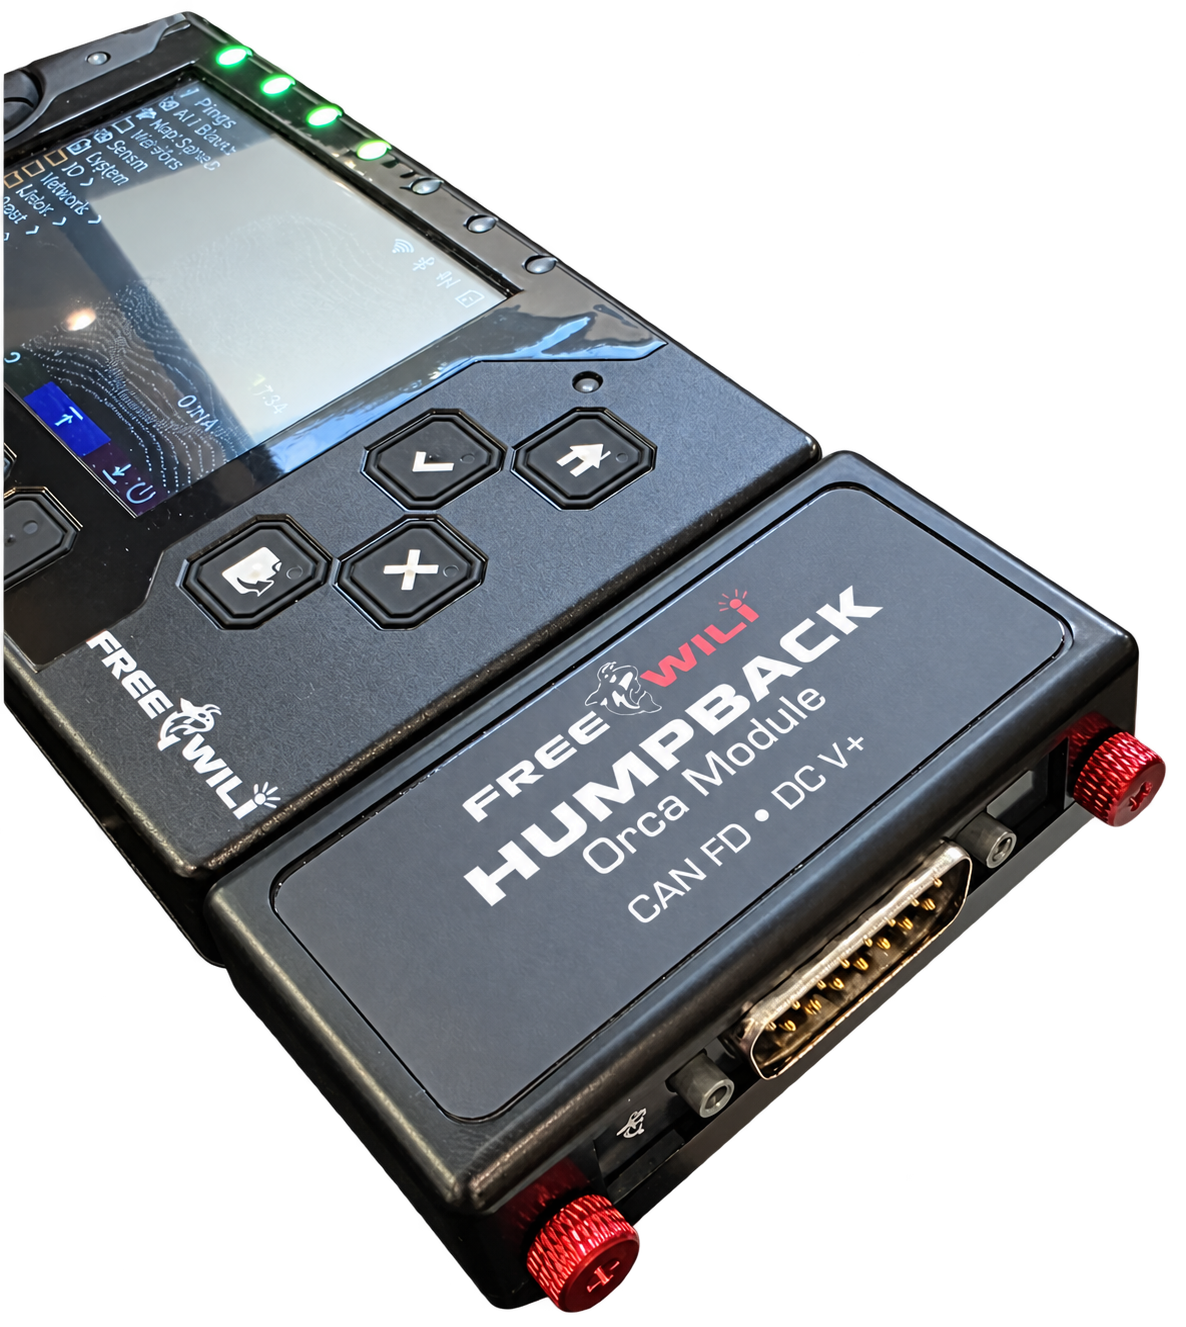
The Humpback Orca is the CAN-only version of SAN DIEGO Orca. It retains the power supply and routes FREE-WILi 2's existing internal CAN interface to a rugged DB-15 connector. It supports CAN and ISO CAN FD through the host's SIC (Signal Improvement Capability) transceiver. The RS485, 10BASE-T1L, 10BASE-T1S, and digital I/O circuitry are omitted.
This is the host's existing CAN channel, with software-selectable CAN termination on FREE-WILi 2. Humpback adds no CAN controller, transceiver, or termination components. Plug it into the FREE-WILi 2 extension connector to access CAN and CAN FD through the DB-15 for logging, scripting, and testing vehicle, robot, and industrial networks.
The DC V+ input is optional and is only needed if you want to power and charge FREE-WILi 2 from an external 5–60 V DC supply.* You can use CAN without connecting DC V+.
CAN and power
- CAN / CAN FD
- Supports CAN and ISO CAN FD using FREE-WILi 2's internal SIC transceiver, routed to DB-15 pins 6 (CAN H) and 14 (CAN L); no additional CAN channel
- CAN termination
- Software-selectable on FREE-WILi 2; Humpback uses the host's termination and adds no termination components
- DC V+ Input
- Optional 5–60 V DC input to power and charge FREE-WILi 2; positive on pin 15, with pin 8 as return*
- Connector
- Rugged DB-15 for clean, secure harness connections in lab, garage, or field
Power input specifications
Humpback retains the SAN DIEGO Orca power supply. Connect DC V+ only when you want to power and charge FREE-WILi 2 from an external DC supply; CAN operation does not require this connection.
- Input voltage
- 5–60 V DC*
- Wiring / polarity
- Supply positive to DB-15 pin 15 (DC V+); supply negative to pin 8 (GND)
- Internal supply
- The on-board buck converter feeds the host's 5 V rail through the extension connector. Internal supply rating: 5 V at 2 A (10 W)
- Supply sizing
- Input current depends on input voltage, load, and conversion losses. The 2 A figure refers to the internal 5 V supply, not a fixed DC V+ input current. Allow voltage headroom above 5 V for a regulated 5 V rail under load
- Power path
- The internal 5 V output includes ideal-diode reverse-current blocking. This is not reverse-polarity protection at the DC V+ input; observe the input polarity
- Ground reference
- Pin 8 is the shared signal and power return, connected to host ground. The power input is not galvanically isolated
* DEF CON FREE-WILi 2 edition: the DC V+ power input does not function.
DB-15 pinout
The view below looks straight into the module's male DB-15 pins with the label facing up. The wide row of eight is on top, with pin 1 at the top left. Only CAN and power connections are used on Humpback.
| Pin | Signal | Description |
|---|---|---|
| 6 | CAN H | FREE-WILi 2 internal CAN / CAN FD high |
| 8 | GND | Shared signal and power return |
| 14 | CAN L | FREE-WILi 2 internal CAN / CAN FD low |
| 15 | DC V+ | Optional 5–60 V DC positive input to power and charge FREE-WILi 2; return on pin 8* |
Pins marked NC in the diagram are unused on Humpback. Its CAN and power connections use the same pin assignments as SAN DIEGO Orca.
Who it is for
- Automotive Teams
- Engineers and test teams logging, replaying, and simulating CAN FD traffic on ECUs and benches
- Security Research
- Researchers exploring vehicle networks with the same portable FREE-WILi workflow used at DEFCON
- Robotics and Industrial
- Developers working with CAN-based motor controllers, sensors, and PLC systems
- Makers and Students
- Learners building real automotive protocol skills on affordable open hardware
CAN with FREE-WILi 2
Humpback brings FREE-WILi 2's internal CAN interface to a DB-15 harness connection. Use it with the host's touchscreen, onboard Linux, Python scripting, and wireless connectivity.
Log bus traffic to a script, display live CAN data on-screen, bridge frames over WiFi, or run a full automated test sequence from your pocket.
Choose SAN DIEGO Orca when you also need RS485, 10BASE-T1L, 10BASE-T1S, or digital I/O.